Japan Aerospace Exploration Agency Launches Martian Moons eXploration Probe
The first surface rover to attempt wheeled movement on a body with extremely weak gravity is set to kick off its interplanetary journey next week, as the Japan Aerospace Exploration Agency dispatches its Martian Moons eXploration probe, according to Aerospace America.
The 4,200-kilogram spacecraft is scheduled to lift off at 4:41 a.m. Japan Standard Time on Oct. 20, which corresponds to 3:41 p.m. Eastern on Oct. 19. The launch begins a yearlong journey to the Martian system. If all goes as planned, the MMX spacecraft will arrive in late 2027. Remote-sensing tools will be employed by the mission to help clarify whether the moons Phobos and Deimos represent debris flung out by an ancient impact with Mars or are instead captured asteroids.
Phobos Regolith Sample Return Target Set for 2031
One of the mission’s main objectives is to acquire 10 grams of regolith from the surface of Phobos. The probe will return this sample to Earth in 2031. This undertaking would secure the initial material ever brought back from the Mars system, barring an earlier arrival by China’s Tianwen-3 Mars sample return, which is likewise scheduled to return in 2031.
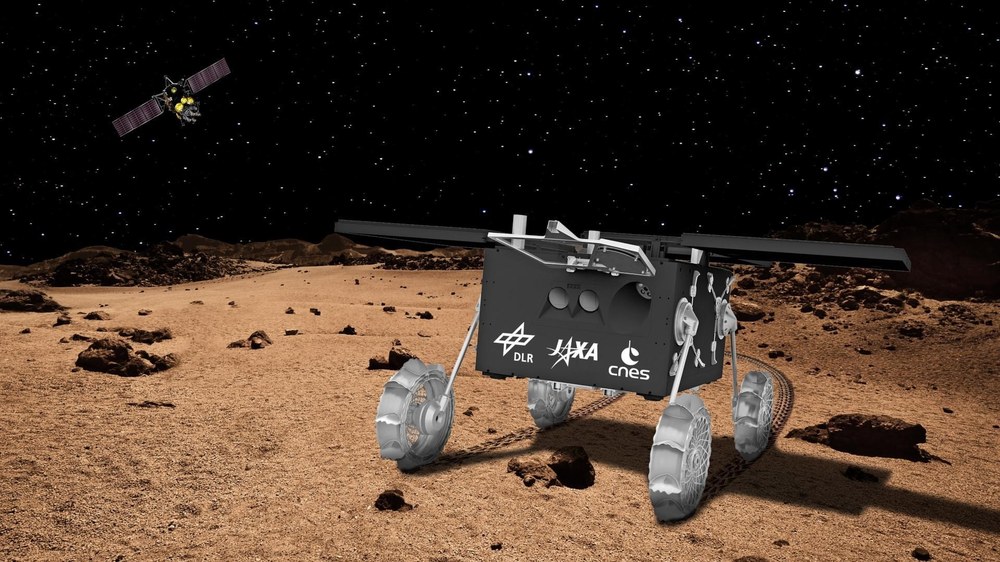
In addition to identifying the best sampling site, the MMX probe will scout out a landing site for Idefix. This 25-kilogram wheeled rover will traverse Phobos for 100 days. It will characterize surface granularity, chemistry, and geology using its ground sensors. The rover marks the first time a vehicle will conduct wheeled driving on an ultra-low gravity body. Previously, only small hopping landers, such as the MINERVA probes deployed by JAXA on a 2018 sampling mission, provided mobility on low-gravity bodies like asteroids.
Engineering Challenges of Operating in Microgravity on Phobos
Gravity on the potato-shaped, 27-kilometer-long Phobos is around 2,000 times lower than on Earth. This creates significant engineering challenges, according to Bastian Deutschmann and Fabian Buse. They serve as chief mission engineers at the German Aerospace Center in Munich, which built Idefix alongside the French space agency CNES.

Idefix has a mass of 25 kilos, but its effective weight on Phobos
will be 12 grams, the same as a grape or a medium-sized envelope,
Deutschmann stated. This extreme reduction in weight affects how the rover is deployed, how it gets upright, and how fast it drives.
Engineers aim to avoid the fate of the European Space Agency’s Philae lander. That lander attempted to reach the surface of comet 67P/Churyumov-Gerasimenko in late 2014, but its anchoring harpoons and hold-down thruster failed. Philae bounced for hours before lodging in a crevasse, where a lack of solar power limited its mission to 60 hours.
Landing Site Mapping and Universal Uprighting Mechanism
To prevent similar bouncing issues with Idefix, the MMX spacecraft will map the surface of Phobos to help select a flat and crater-free landing site, Deutschmann explained. MMX will release Idefix from an altitude of 40 meters. The rover will impact the surface at 1 meter per second, or 2.2 mph. This speed stays well below Phobos’ 10 m/s escape velocity, ensuring Idefix does not bounce back into space. Officials at the German Aerospace Center anticipate that the rover will execute surface bounces for approximately 15 minutes and cover a span of several tens of meters before finally coming to a halt.
If Idefix settles on its side, a universal uprighting mechanism developed by the CNES team led by rover engineer Brysbaert Clement will reorient the vehicle. The design places wheels at the end of extendable arms. Each arm connects to 360-degree electrically rotatable shoulders that swing the legs to either side of the chassis, allowing the rover to right itself regardless of its resting position.
Solar Panel Deployment and Glacial Driving Speeds
Once upright, three solar panels will fold out sequentially from the top of the box-like rover, deploying to the rear, left, and right of the chassis. If the sun angle does not allow for flat deployment to capture maximum energy, the individually rotatable legs can move to angle the rover toward the sun. Buse noted this capability is critical because without power to warm electronic systems, night temperatures reaching minus 150 degrees Celsius would freeze, embrittle, and destroy the rover’s circuits.
Should uprighting succeed, Idefix must maintain a glacial speed of just 1 mm/s, Deutschmann said. In an emergency stop, we must not fall over forwards, so that puts a hard limit on our upper velocity.
That limit is 5 cm/s, but Idefix will travel much slower to prevent it from entering risky terrain during periods when it is out of contact with mission control.
WheelCam Analysis of Regolith Behavior in Microgravity
Locomotion is not the only function of the rover’s wheels. Idefix carries a pair of WheelCams aimed at the points where the front and rear left wheels meet the soil. These allow scientists to understand how the regolith behaves and flows in microgravity,
Deutschmann stated. By observing how regolith tumbles off the grousers—the grip-providing lugs stationed around the wheel’s diameter—scientists can estimate grain size, shape, cohesion, and soil compaction.
Dan Negrut, a surface rover specialist at the University of Wisconsin-Madison, called that data priceless for future lander missions to Phobos. The WheelCams should provide a rich record of the soil’s mechanical behavior,
Negrut said.
Frequently Asked Questions
When is the MMX spacecraft scheduled to launch?
The 4,200-kilogram spacecraft is scheduled to lift off at 4:41 a.m. Japan Standard Time on Oct. 20, which translates to 3:41 p.m. Eastern on Oct. 19.
What are the primary targets of the Martian Moons eXploration mission?
The mission aims to determine whether Phobos and Deimos are captured asteroids or ejecta from an ancient collision with Mars, while also acquiring 10 grams of Phobos regolith for return to Earth in 2031.
How fast is the Idefix rover designed to drive on Phobos?
Idefix will travel at a glacial speed of 1 mm/s, staying well under its hard upper velocity limit of 5 cm/s to prevent it from tipping forward during an emergency stop.